 2021, Vol. 38


The theory of minimal surfaces is an important part of modern differential geometry. The theory is particularly fruitful when the ambient space is a symmetric space. Calabi[1] proved a rigidity theorem for minimal two-spheres of constant curvature in Sn. Bolton et al.[2] constructed all the minimal two-spheres of constant curvature in
In this paper, we present a construction of the complex Grassmannian G(2, n+2) due to Berndt[4], which considers G(2, n+2) as a quotient of some minimal submanifold Qn+1 of
Our result is a special case of Ref.[5], where the author considered a general Riemannian submersion N→B, and characterized the existence of horizontal lifts of a submanifold of B using a family J of (1, 1)-tensors on B. In our paper, we make use of the fact that the projection Qn+1→G(2, n+2) is a principal bundle, thus obtain a characterization by a first order PDE. Our method is largely inspired by Ref.[3], where the authors considered the Riemannian submersion S4n+3→
We denote by
| $ \mathrm{i}^{2}=\mathrm{j}^{2}=\mathrm{k}^{2}=-1, $ |
| $ \mathrm{ij}=\mathrm{k}=-\mathrm{ji}, \mathrm{jk}=\mathrm{i}=-\mathrm{kj}, \mathrm{ki}=\mathrm{j}=-\mathrm{ik} . $ |
Thus
| $ \mathbb{R}=\mathbb{R} \cdot 1 \subset \mathbb{H}, \quad \mathbb{C}=\mathbb{R} \cdot 1 \oplus \mathbb{R} \cdot \mathrm{i} \subset \mathbb{H}, $ |
and we sometimes express an element of
Conjugation is defined for quaternions:
| $ \overline{a+b \mathrm{i}+c \mathrm{j}+d \mathrm{k}}=a-b \mathrm{i}-c \mathrm{j}-d \mathrm{k}(a, b, c, d \in \mathbb{R}). $ |
Or equivalently,
| $ \overline{z+w \mathrm{j}}=\bar{z}-w \mathrm{j}(z, w \in \mathbb{C}). $ |
Then we have pq=qp, for any p, q∈
Let
| $ \langle\boldsymbol{p}, \boldsymbol{q}\rangle_{\mathbb{H}}=\sum\limits_{l} \bar{p}_{l} q_{l},\langle\boldsymbol{p}, \boldsymbol{q}\rangle_{\mathbb{R}}=\operatorname{Re}\langle\boldsymbol{p}, \boldsymbol{q}\rangle_{\mathbb{H}}. $ |
It is easily verified that 〈, 〉
| $ \langle\boldsymbol{p} x, \boldsymbol{q} y\rangle_{\mathbb{H}} =\bar{x}\langle\boldsymbol{p}, \boldsymbol{q}\rangle_{\mathbb{H}} y, $ |
| $ \langle\boldsymbol{p}, \boldsymbol{q}\rangle_{\mathbb{H}} =\overline{\langle\boldsymbol{q}, \boldsymbol{p}\rangle}_{\mathbb{H}}, $ |
where p, q∈
Similarly, for z=(z1, …, zn)t, w=(w1, …, wn)t∈
| $ \langle \boldsymbol{z}, \boldsymbol{w}\rangle_{\mathbb{C}}=\sum\limits_{1} \overline{\mathrm{z}}_{1} \mathrm{w}_{1},\langle \boldsymbol{z}, \boldsymbol{w}\rangle_{\mathbb{R}}=\operatorname{Re}\langle \boldsymbol{z}, \boldsymbol{w}\rangle_{\mathbb{C}}. $ |
We will often omit the subscripts
Next we consider the quaternion projective space
We quote some results from Ref.[4].
SU(n+2) acts on S4n+7⊂
| $ S U(n+2) \times S^{4 n+7} \rightarrow S^{4 n+7}, $ |
| $ (\boldsymbol{A}, \boldsymbol{z}+\boldsymbol{v} \mathrm{j}) \mapsto \boldsymbol{A} \boldsymbol{z}+(\boldsymbol{A} \boldsymbol{v}) \mathrm{j}, $ |
where z, v∈
By some straightforward calculations, we find that this SU(n+2)-action on
| $ \mathbb{C} P^{n+1}=\left\{\boldsymbol{\tau}(\boldsymbol{z}+0 \cdot \mathrm{j}) \mid \boldsymbol{z} \in S^{2 n+3}\right\}, $ | (1) |
and
| $ \begin{aligned} Q^{n+1} &=\{\boldsymbol{\tau}((1 / \sqrt{2})(\boldsymbol{z}+\boldsymbol{v} \mathrm{j})) \mid \boldsymbol{z},\\ \boldsymbol{v} &\left.\in S^{2 n+3},\langle \boldsymbol{z}, \boldsymbol{v}\rangle=0\right\}, \end{aligned} $ | (2) |
where S2n+3 is the unit sphere of
We have the following proposition from Ref.[4]:
Proposition 2.1 The singular orbits of the SU(n+2)-action on
Now consider an action of U(1) on Qn+1:
| $ U(1) \times Q^{n+1} \rightarrow Q^{n+1},\left(\mathrm{e}^{\mathrm{i} t}, \boldsymbol{\tau}(\boldsymbol{q})\right) \mapsto \boldsymbol{\tau}\left(\mathrm{e}^{\mathrm{i} t} \boldsymbol{q}\right), $ |
where t∈
| $ \begin{aligned} \boldsymbol{\xi}_{\boldsymbol{\tau}(\boldsymbol{q})} &=\left.\frac{\mathrm{d}}{\mathrm{d} t}\right|_{t=0} \mathrm{e}^{\mathrm{i} t} \cdot \boldsymbol{\tau}(\boldsymbol{q})=\left.\frac{\mathrm{d}}{\mathrm{d} t}\right|_{t=0} \boldsymbol{\tau}\left(\mathrm{e}^{\mathrm{i} t} \boldsymbol{q}\right) \\ &=\mathrm{d} \boldsymbol{\tau}_{\boldsymbol{q}}(\mathrm{i} \boldsymbol{q})=\boldsymbol{\tau}_{\boldsymbol{q}}(\mathrm{i} \boldsymbol{q}). \end{aligned} $ | (3) |
Here
Let Bn+1=Qn+1/U(1). Since U(1) acts on Qn+1 isometrically, there is a unique Riemannian metric on Bn+1 such that the natural projection π: Qn+1→Bn+1 is a Riemannian submersion.
For τ(q)∈Qn+1, let
| $ \boldsymbol{\tau}_{\boldsymbol{q}}^{-1} \mathcal{H}_{\boldsymbol{\tau}(\boldsymbol{q})}=\left\{\boldsymbol{X} \in \mathbb{H}^{n+2} \mid\langle\boldsymbol{X}, \boldsymbol{q}\rangle=\langle\boldsymbol{X}, \mathrm{i} \boldsymbol{q}\rangle=0\right\}. $ | (4) |
We define a (1, 1)-tensor φ on Qn+1 as φX=
| $ \varphi X= \begin{cases}0, & \boldsymbol{X}=\boldsymbol{\xi}, \\ \boldsymbol{\tau}_{\boldsymbol{q}}\left(-\mathrm{i} \cdot \boldsymbol{\tau}_{\boldsymbol{q}}^{-1}(\boldsymbol{X})\right), & \boldsymbol{X} \in \mathcal{H}_{\boldsymbol{\tau}(\boldsymbol{q})} .\end{cases} $ | (5) |
Since by definition Tτ(q)Qn+1=
Finally, notice that φ commutes with the U(1)-action on Qn+1. In other words, if Lt denotes the map Qn+1→Qn+1,
| $ G(2, n+2)=U(n+2) / U(2) \times U(n), $ |
where the metric on G(2, n+2) is induced by the following bi-invariant metric on U(n+2):
| $ \langle\boldsymbol{X}, \boldsymbol{Y}\rangle=-\frac{1}{4} \operatorname{tr}(\boldsymbol{X} \boldsymbol{Y}),(\boldsymbol{X}, \boldsymbol{Y} \in \mathfrak{U}(n+2)). $ |
Thus, for example, B2 is isometric to G(2, 3)=
Remark The isometry between G(2, n+2) and Bn+1 can be explicitly given as
| $ G(2, n+2) \rightarrow B^{n+1}, $ |
| $ \mathbb{C} \boldsymbol{z} \oplus \mathbb{C} \boldsymbol{v} \mapsto \boldsymbol{\pi}\left(\boldsymbol{\tau}\left(\frac{1}{\sqrt{2}}(\boldsymbol{z}+\boldsymbol{v} \mathrm{j})\right)\right), $ |
where z, v∈
Definition 3.1 Suppose N is a Hermitian manifold, J is its complex structure, f: M→N is an immersion from a surface M to N. Then f is called totally real if J Im f*p⊥Imf*p for all p∈M.
If we choose a local frame X, Y for M, then fis totally real if and only if Jf*X⊥f*Y everywhere. This follows easily from the Hermitian condition 〈Ju, Jv〉=〈u, v〉, J2=-1, where 〈, 〉 is the Riemannian metric on N.
Now we can state our main result.
Theorem 3.1 Suppose M is a surface, ψ: M→Bn+1 an immersion, then the following are equivalent:
1) ψ is totally real;
2) ψ has local horizontal lifts to Qn+1, that is, for any p∈M, there is a neighborhood U of p, and an immersion η: U→Qn+1, such that
Furthermore, η is minimal in Qn+1 if and only if ψ is minimal in Bn+1.
We prove the theorem step by step.
Step 1 Let U be an open subset of M, η: U→Qn+1 an immersion, we shall find a sufficient and necessary condition for η to be horizontal.
First, since τ: S4n+7→
| $ \begin{aligned} \mathrm{d} \eta &=\mathrm{d} \boldsymbol{\tau} \mathrm{d} \boldsymbol{q} \\ &=\mathrm{d} \boldsymbol{\tau}(\mathrm{d} \boldsymbol{q}-\boldsymbol{q}\langle\boldsymbol{q}, \mathrm{d} \boldsymbol{q}\rangle), \end{aligned} $ | (6) |
so the horizontal lift of dη to S4n+7 is τq-1dη=dq-q〈q, dq〉, namely the orthogonal projection of dq onto Hq, the horizontal space of τ at q.
Recall from the last section that
η is horizontal with respect to π
For the last equivalence note that q∈τ-1(Qn+1) implies 〈q, iq〉=0.
Write
| $ \left\{\begin{array}{l} \langle\mathrm{d} \boldsymbol{V}, \boldsymbol{V}\rangle+\langle\boldsymbol{V}, \mathrm{d} \boldsymbol{V}\rangle=0, \\ \langle\mathrm{d} \boldsymbol{Z}, \boldsymbol{V}\rangle+\langle\boldsymbol{Z}, \mathrm{d} \boldsymbol{V}\rangle=0. \end{array}\right. $ |
Then
| $ \begin{aligned} \langle&\mathrm{d} \boldsymbol{q}, \mathrm{i} \boldsymbol{q}\rangle=0 \\ \Leftrightarrow 0=&\langle\mathrm{d} \boldsymbol{Z}+\mathrm{d} \boldsymbol{V} \cdot \mathrm{j}, \boldsymbol{Z} \mathrm{i}+\boldsymbol{V} \boldsymbol{\mathrm { k }}\rangle \\ =&(\langle\mathrm{d} \boldsymbol{Z}, \boldsymbol{Z}\rangle-\langle\boldsymbol{V}, \mathrm{d} \boldsymbol{V}\rangle) \mathrm{i}+\\ &(\langle\boldsymbol{Z}, \mathrm{d} \boldsymbol{V}\rangle+\langle\mathrm{d} \boldsymbol{Z}, \boldsymbol{V}\rangle) \mathrm{k} \\ =&(\langle\mathrm{d} \boldsymbol{Z}, \boldsymbol{Z}\rangle+\langle\mathrm{d} \boldsymbol{V}, \boldsymbol{V}\rangle) \mathrm{i} . \end{aligned} $ |
In summary, we have proved
Lemma 3.1 Suppose
| $ \langle\mathrm{d} \boldsymbol{Z}, \boldsymbol{Z}\rangle+\langle\mathrm{d} \boldsymbol{V}, \boldsymbol{V}\rangle=0. $ | (7) |
Step 2 Let ψ: M→Bn+1 be an immersion of a surface M into Bn+1. We look for the condition under which ψ has a local horizontal lift to Qn+1.
Let
| $ \eta_{0}=\lambda \cdot \eta=\boldsymbol{\tau}\left(\frac{1}{\sqrt{2}}(\lambda \boldsymbol{Z}+\lambda \boldsymbol{V} \mathrm{j})\right). $ | (8) |
Since η0 is horizontal, we apply Lemma 1 to obtain
| $ \begin{aligned} 0 &=\langle\mathrm{d}(\lambda \boldsymbol{Z}), \lambda \boldsymbol{Z}\rangle+\langle\mathrm{d}(\lambda \boldsymbol{V}), \lambda \boldsymbol{V}\rangle \\ &=\langle\mathrm{d} \lambda \cdot \boldsymbol{Z}+\lambda \mathrm{d} \boldsymbol{Z}, \lambda \boldsymbol{Z}\rangle+\langle\mathrm{d} \lambda \cdot \boldsymbol{V}+\lambda \mathrm{d} \boldsymbol{V}, \lambda \boldsymbol{V}\rangle \\ &=\lambda \mathrm{d} \bar{\lambda}(\langle\boldsymbol{Z}, \boldsymbol{Z}\rangle+\langle\boldsymbol{V}, \boldsymbol{V}\rangle)+\lambda \bar{\lambda}(\langle\mathrm{d} \boldsymbol{Z}, \boldsymbol{Z}\rangle+\langle\mathrm{d} \boldsymbol{V}, \boldsymbol{V}\rangle) \\ &=-2 \bar{\lambda} \mathrm{d} \lambda+\langle\mathrm{d} \boldsymbol{Z}, \boldsymbol{Z}\rangle+\langle\mathrm{d} \boldsymbol{V}, \boldsymbol{V}\rangle. \end{aligned} $ |
Here we have used λλ=1 and λdλ+λdλ=0. Since λdλ=λ-1dλ=d(logλ) we get
| $ 2 \mathrm{~d}(\log \lambda)=\langle\mathrm{d} \boldsymbol{Z}, \boldsymbol{Z}\rangle+\langle\mathrm{d} \boldsymbol{V}, \boldsymbol{V}\rangle. $ | (9) |
If we take a local coordinate (x, y) on M, this amounts to
| $ \left\{\begin{array}{l} 2 \frac{\partial \log {\lambda}}{\partial x}=\left\langle\boldsymbol{Z}_{x}, \boldsymbol{Z}\right\rangle+\left\langle\boldsymbol{V}_{x}, \boldsymbol{V}\right\rangle, \\ 2 \frac{\partial \log \lambda}{\partial y}=\left\langle\boldsymbol{Z}_{y}, \boldsymbol{Z}\right\rangle+\left\langle\boldsymbol{V}_{y}, \boldsymbol{V}\right\rangle, \end{array}\right. $ | (10) |
where
| $ \frac{\partial}{\partial y}\left(\frac{\partial \log \lambda}{\partial x}\right)=\frac{\partial}{\partial x}\left(\frac{\partial \log \lambda}{\partial y}\right), $ |
that is,
| $ \frac{\partial}{\partial y}\left(\left\langle\boldsymbol{Z}_{x}, \boldsymbol{Z}\right\rangle+\left\langle\boldsymbol{V}_{x}, \boldsymbol{V}\right\rangle\right)=\frac{\partial}{\partial x}\left(\left\langle\boldsymbol{Z}_{y}, \boldsymbol{Z}\right\rangle+\left\langle\boldsymbol{V}_{y}, \boldsymbol{V}\right\rangle\right) $ |
holds. This equation simplifies to
| $ \left\langle\boldsymbol{Z}_{x}, \boldsymbol{Z}_{y}\right\rangle+\left\langle\boldsymbol{V}_{x}, \boldsymbol{V}_{y}\right\rangle=\left\langle\boldsymbol{Z}_{y}, \boldsymbol{Z}_{x}\right\rangle+\left\langle\boldsymbol{V}_{y}, \boldsymbol{V}_{x}\right\rangle . $ | (11) |
Thus we obtain
Lemma 3.2 Suppose
Step 3 Let
We have
| $ \begin{aligned} \mathrm{d} \psi &=\mathrm{d} \pi \mathrm{d} \boldsymbol{\tau} \mathrm{d} \boldsymbol{q} \\ &=\mathrm{d} \pi \mathrm{d} \boldsymbol{\tau}(\mathrm{d} \boldsymbol{q}-\boldsymbol{q}\langle\boldsymbol{q}, \mathrm{d} \boldsymbol{q}\rangle-\mathrm{i} \boldsymbol{q}\langle\mathrm{i} \boldsymbol{q}, \mathrm{d} \boldsymbol{q}\rangle) \\ &=\mathrm{d} \pi \mathrm{d} \boldsymbol{\tau}\left(\mathrm{d} \boldsymbol{q}^{\mathcal{H}}\right), \end{aligned} $ | (12) |
where
Choose a local coordinate (x, y) on M. Then, using the definitions of the tensors φ, J (see (5)), and the fact that τ, π are Riemannian submersions, we obtain
ψ is totally real
| $ \begin{aligned} \Leftrightarrow 0 &=\left\langle\psi_{x}, J \psi_{y}\right\rangle_{B^{n+1}} \\ &=\left\langle\pi_{\boldsymbol{\tau}(\boldsymbol{q})}^{-1} \psi_{x}, \pi_{\boldsymbol{\tau}(\boldsymbol{q})}^{-1} J \psi_{y}\right\rangle_{Q^{n+1}} \\ &=\left\langle{\pi}_{\boldsymbol{\tau}(\boldsymbol{q})}^{-1} \psi_{x}, {\varphi} \pi_{\boldsymbol{\tau}(\boldsymbol{q})}^{-1} \psi_{y}\right\rangle_{Q^{n+1}} \\ &=\left\langle\boldsymbol{\tau}_{\boldsymbol{q}}^{-1} \pi_{\boldsymbol{\tau}(\boldsymbol{q})}^{-1} \psi_{x}, \boldsymbol{\tau}_{\boldsymbol{q}}^{-1} \varphi \pi_{\boldsymbol{\tau}(\boldsymbol{q})}^{-1} \psi_{y}\right\rangle_{\mathbb{R}} \\ &=\left\langle\boldsymbol{\tau}_{\boldsymbol{q}}^{-1} \pi_{\boldsymbol{\tau}(\boldsymbol{q})}^{-1} \psi_{x},-\mathrm{i} \cdot \boldsymbol{\tau}_{\boldsymbol{q}}^{-1} \pi_{\boldsymbol{\tau}(\boldsymbol{q})}^{-1} \psi_{y}\right\rangle_{\mathbb{R}} \\ &=\left\langle\boldsymbol{q}_{x}^{\mathcal{H}},-\mathrm{i} \boldsymbol{q}_{y}^{\mathcal{H}}\right\rangle_{\mathbb{R}} . \end{aligned} $ | (13) |
Since
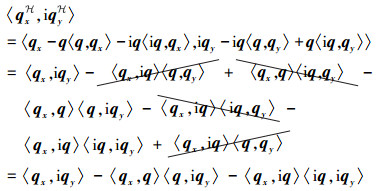
|
For the second step note that q∈τ-1(Qn+1) implies 〈q, iq〉=0. Differentiating〈q, q〉=1 yields
| $ \begin{aligned} 0 &=\left\langle\boldsymbol{q}_{x}, \boldsymbol{q}\right\rangle+\left\langle\boldsymbol{q}, \boldsymbol{q}_{x}\right\rangle \\ &=\left\langle\boldsymbol{q}_{x}, \boldsymbol{q}\right\rangle+\overline{\left\langle\boldsymbol{q}_{x}, \boldsymbol{q}\right\rangle}, \end{aligned} $ |
i.e., 〈qx, q〉∈Im
| $ \begin{aligned} 0 &=\left\langle\boldsymbol{q}_{y}, \mathrm{i} \boldsymbol{q}\right\rangle+\left\langle\boldsymbol{q}, \mathrm{i} \boldsymbol{q}_{y}\right\rangle \\ &=-\left\langle\mathrm{i} \boldsymbol{q}_{y}, \boldsymbol{q}\right\rangle+\left\langle\boldsymbol{q}, \mathrm{i} \boldsymbol{q}_{y}\right\rangle \\ &=-\overline{\left\langle\boldsymbol{q}, \mathrm{i} \boldsymbol{q}_{y}\right\rangle}+\left\langle\boldsymbol{q}, \mathrm{i} \boldsymbol{q}_{y}\right\rangle, \end{aligned} $ |
i.e., 〈q, iqy〉∈
| $ \begin{aligned} & 2\left\langle\boldsymbol{q}_{x}^{\mathcal{H}}, \mathrm{i} \boldsymbol{q}_{y}^{\mathcal{H}}\right\rangle_{\mathbb{R}} \\ =& 2 \operatorname{Re}\left\langle\boldsymbol{q}_{x}^{\mathcal{H}}, \mathrm{i} \boldsymbol{q}_{y}^{\mathcal{H}}\right\rangle \\ =& 2 \operatorname{Re}\left\langle\boldsymbol{q}_{x}, \mathrm{i} \boldsymbol{q}_{y}\right\rangle \\ =& \operatorname{Re}\left\langle\boldsymbol{Z}_{x}+\boldsymbol{V}_{x} \mathrm{j}, \boldsymbol{Z}_{y} \mathrm{i}+\boldsymbol{V}_{y} \mathrm{k}\right\rangle \\ =& \operatorname{Re}\left(\left\langle\boldsymbol{Z}_{x}, \boldsymbol{Z}_{y}\right\rangle \mathrm{i}-\left\langle\boldsymbol{V}_{y}, \boldsymbol{V}_{x}\right\rangle \mathrm{i}\right) \\ =& \operatorname{Im}\left(\left\langle\boldsymbol{V}_{y}, \boldsymbol{V}_{x}\right\rangle-\left\langle\boldsymbol{Z}_{x}, \boldsymbol{Z}_{y}\right\rangle\right) . \end{aligned} $ | (14) |
Finally, from (13) and (14) we obtain
Lemma 3.3
| $ \operatorname{Im}\left(\left\langle\boldsymbol{V}_{y}, \boldsymbol{V}_{x}\right\rangle-\left\langle\boldsymbol{Z}_{x}, \boldsymbol{Z}_{y}\right\rangle\right)=0, $ |
or equivalently,
| $ \left\langle\boldsymbol{V}_{y}, \boldsymbol{V}_{x}\right\rangle-\left\langle\boldsymbol{Z}_{x}, \boldsymbol{Z}_{y}\right\rangle=\left\langle\boldsymbol{V}_{x}, \boldsymbol{V}_{y}\right\rangle-\left\langle\boldsymbol{Z}_{y}, \boldsymbol{Z}_{x}\right\rangle $ | (15) |
Comparing with Lemma 3.2, we find that ψ have a local horizontal lift to Qn+1 if and only if it is totally real.
Step 4 We need a simple lemma.
Lemma 3.4 Suppose
| $ \boldsymbol{H}_{M}(\pi(p))=\pi_{*}\left(\boldsymbol{H}_{\bar{M}}(p)\right) $ |
for any p∈M. Furthermore, HM is horizontal. Here HM, HM are the mean curvature vectors of M, M, respectively.
Proof Let e1, …, em be an orthonormal frame on M, then, since
| $ \begin{aligned} \nabla_{\boldsymbol{e}_{i}}^{N} \boldsymbol{e}_{i} &=\pi_{*}\left(\nabla_{\bar{\boldsymbol{e}}_{i}}^{\bar{N}} \overline{\boldsymbol{e}}_{i}\right) \\ &=\pi_{*}\left(\nabla_{\bar{\boldsymbol{e}}}^{\bar{M}} \overline{\boldsymbol{e}}_{i}+\boldsymbol{B}_{\bar{M}}\left(\overline{\boldsymbol{e}}_{i}, \overline{\boldsymbol{e}}_{i}\right)\right) \\ &=\nabla_{\boldsymbol{e}_{i}}^{M} \boldsymbol{e}_{i}+\pi_{*}\left(\boldsymbol{B}_{\bar{M}}\left(\overline{\boldsymbol{e}}_{i}, \overline{\boldsymbol{e}}_{i}\right)\right). \end{aligned} $ | (16) |
Comparing with the Gauss equation in N, we find that
| $ \boldsymbol{B}_{M}\left(\boldsymbol{e}_{i}, \boldsymbol{e}_{i}\right)=\pi_{*}\left(\boldsymbol{B}_{\bar{M}}\left(\overline{\boldsymbol{e}}_{i}, \overline{\boldsymbol{e}}_{i}\right)\right). $ | (17) |
The conclusion follows immediately.
From the above lemma, we see that HM=
| [1] |
Calabi E. Minimal immersions of surfaces in Euclidean spheres[J]. Journal of Differential Geometry, 1967, 1(1): 111-125. |
| [2] |
Bolton J, Jensen G R, Rigoli M, et al. On conformal minimal immersions of S2 into |
| [3] |
He Y, Wang C. Totally real minimal 2-spheres in quaternionic projective space[J]. Science in China. Series A. Mathematics, 2005, 48(3): 341-349. DOI:10.1360/03ys0295 |
| [4] |
Berndt J. Riemannian geometry of complex two-plane Grassmannians[J]. Rendiconti del Seminario Matematico. Università e Politecnico Torino, 1997, 55(1): 19-83. |
| [5] |
Reckziegel H. Horizontal lifts of isometric immersions into the bundle space of a pseudo-Riemannian submersion[C]//Ferus D, Gardner R B, Helgason S, et al. Global differential geometry and global analysis 1984. Berlin: Springer, 1985: 264-279.
|
| [6] |
Petersen P. Riemannian geometry[M]. 3rd ed. Berlin: Springer, 2016.
|